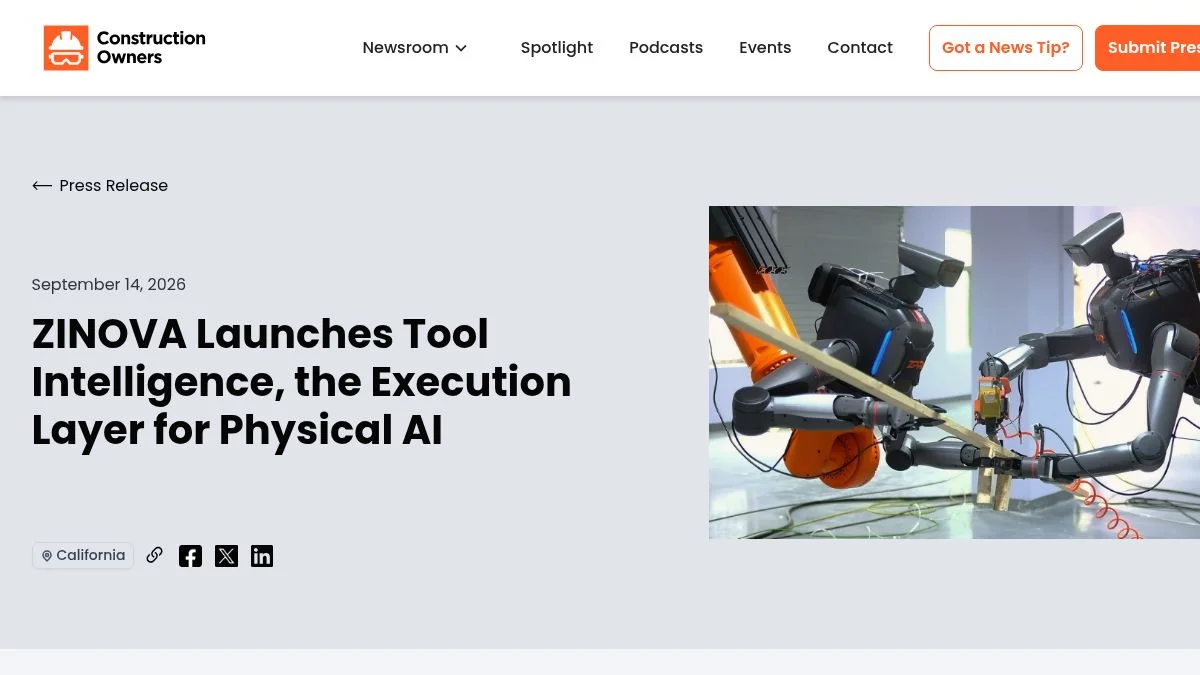
ZINOVA has launched Tool Intelligence, a physical-AI system intended to help robots recognize, grasp, sense and operate tools across different robotic forms. The company presented the system in a construction demonstration involving a steel-reinforced concrete tilt-up panel.
A tool-use layer for physical AI
The September 14 announcement describes Tool Intelligence as an execution layer that connects perception, grasping and tool operation. The stated aim is to let robots use existing tools rather than requiring a separate purpose-built end effector for each workflow.
Construction is the first public demonstration
ZINOVA’s public demo shows robots working with construction equipment on a steel-reinforced concrete panel. The company also identifies Grasp, TEISI and The Third Form as related research areas and names LimX Dynamics, KUKA and RIC Robotics among its partners.
What remains unproven
The release establishes a product launch and a public demonstration, not broad production deployment. It does not provide independent success rates, customer-scale uptime, safety results or evidence that the system generalizes across tools, environments and robot hardware.