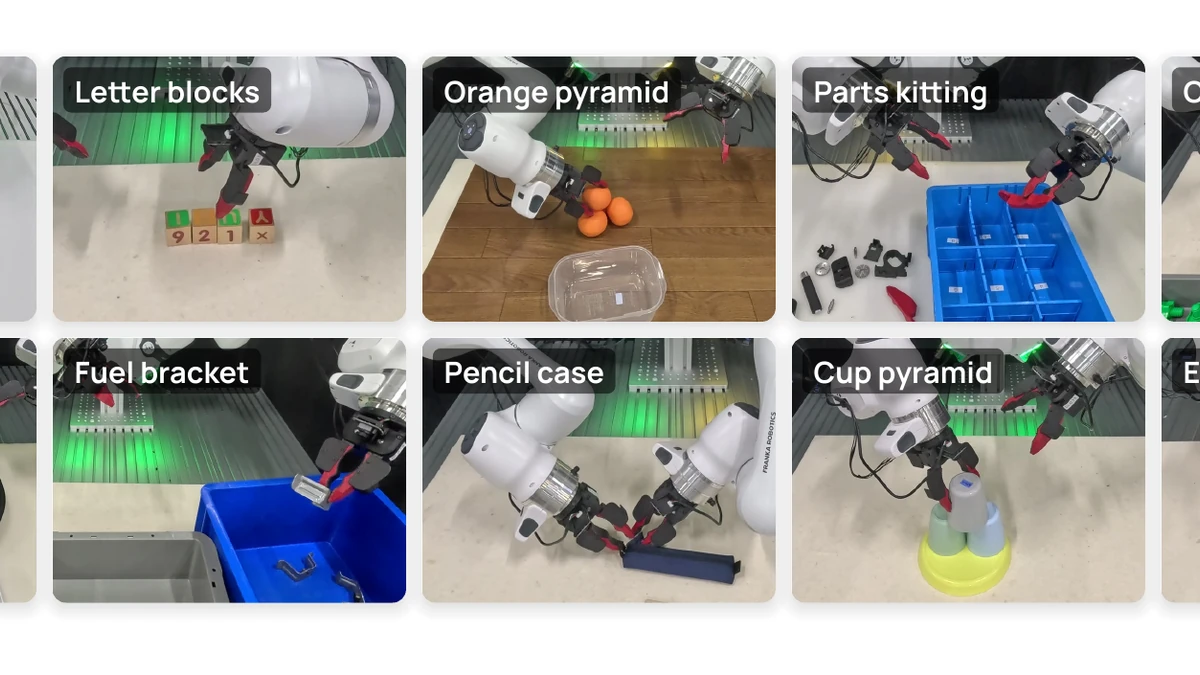
AIRoA released its A-0 robot foundation model on November 6, using manipulation demonstrations collected by people holding YUBI grippers rather than teleoperating robots. The release includes pre-trained and post-trained weights and related code for research and development.
Starting from Physical Intelligence’s π0.5 base weights, AIRoA used 16,151 hours of YUBI data. The devices record video and gripper trajectories during human manipulation. The organization says this training did not use reinforcement learning or on-robot corrections.
In AIRoA’s evaluation, A-0 averaged 78% success across ten tasks tested 15 times each, compared with 27% for the strongest of four comparison models post-trained on the same data. These are developer-run results under specified conditions, not proof of reliable operation across arbitrary homes or factories.
A-0 outputs gripper positions and orientations that each robot’s control system converts into motion. AIRoA reports operation on four dual-arm platforms fitted with YUBI. The release creates a reproducible starting point for outside testing, but the underlying training dataset is still planned for later release, with timing and scope to be announced.